Camera-grounded context
Overhead and wrist views feed a planner while joint observations keep the action interface explicit.
TABLEMATE · PRODUCT DEMO
An inspectable MuJoCo workstation for coordinating two SO-101 arms around a dinner table.
Watch the evidence ↓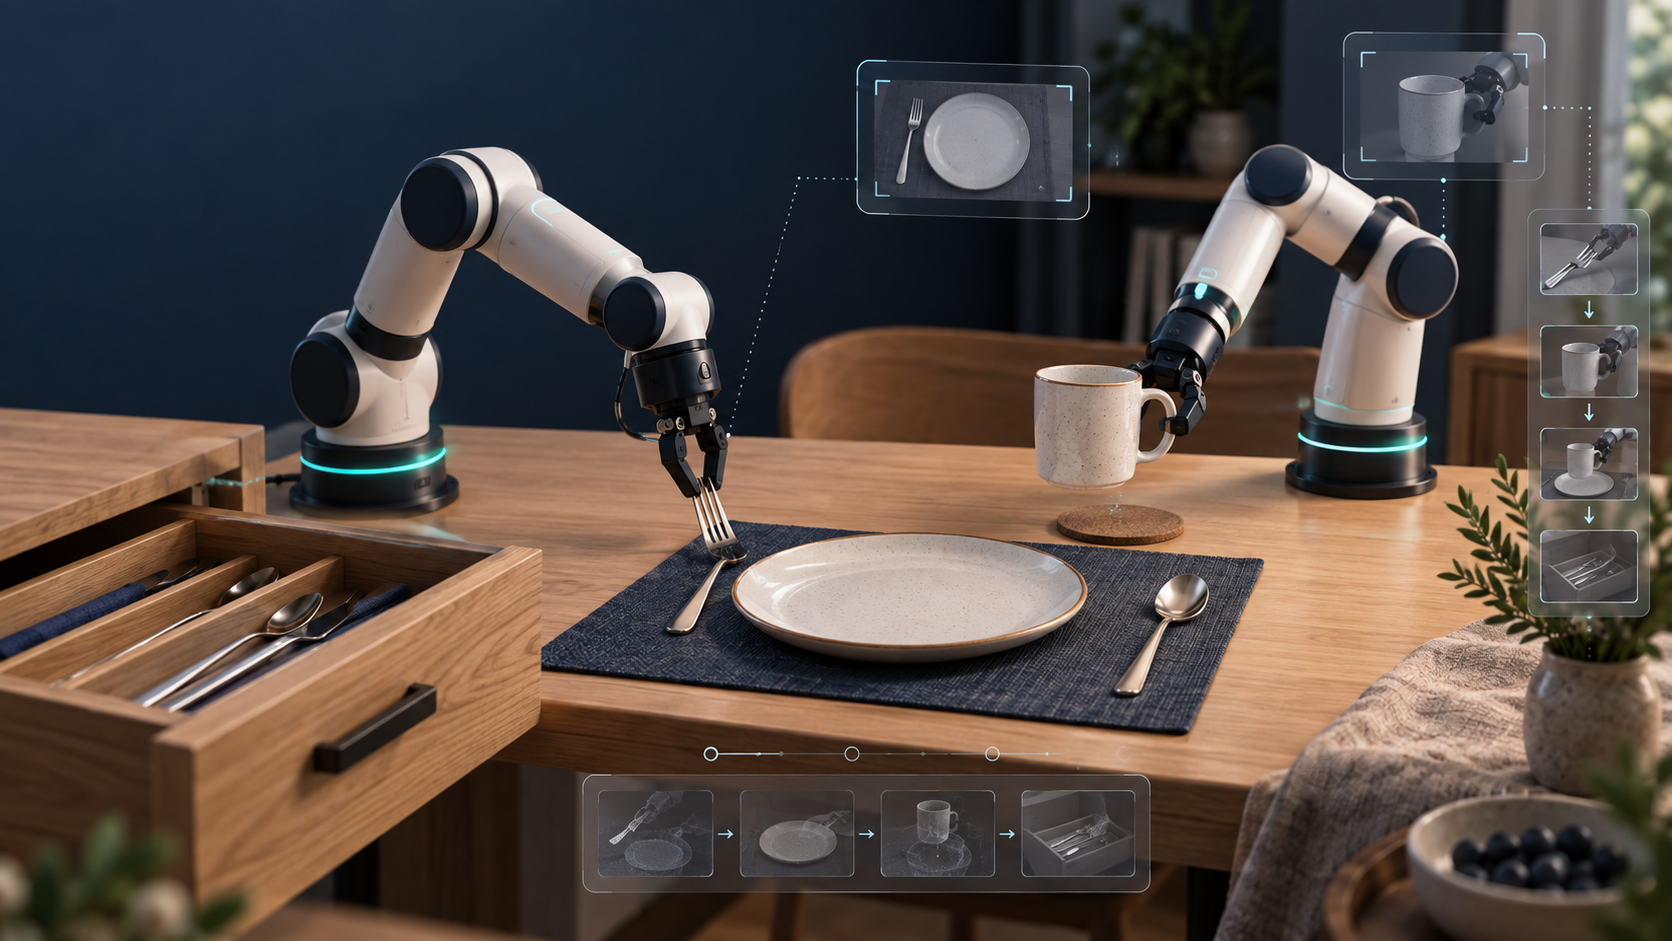
HOW IT WORKS
Overhead and wrist views feed a planner while joint observations keep the action interface explicit.
Supported skills, prerequisites, arm ownership, timeouts, and cancellation are checked before execution.
MuJoCo contacts represent grasps and hand-offs. Invalid or unsafe actions stop the run.
RECORDED EVIDENCE
These frames show a sealed contact-based teacher correction run. The repository preserves synchronized observations, actions, contacts, and outcome records for inspection.
58-second MuJoCo teacher-evidence replay · source and manifests in the repository
REPRODUCE
Use the submission handoff for exact evidence boundaries, local commands, and artifact lineage. Explore the learning path to understand the system from first principles.